Real outputs
Open a model CADlingo made
Explore saved models generated with CADlingo. Open one in the Studio to inspect its shape, view cross sections, and try the dimension controls it provides.
85 models
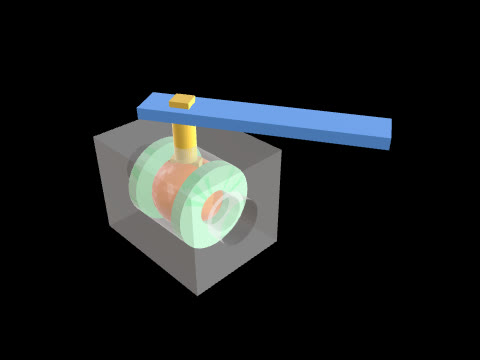
“레버식 볼밸브를 30° 열린 상태로, 분리된 솔리드 6개(몸체, 볼, 시트 링 2개, 스템, 핸들)로 만들어줘. 좌표계: 유로 축 = X축, 볼 중심 = 원점, 스템 축 = Z축. 방향 d = (cos30°, sin30°, 0) = (0.86603, 0.5, 0) 은 볼 구멍과 핸들 방향, e = (-0.5, 0.86603, 0) 은 그에 수직인 수평 방향. (1) 몸체 (한 솔리드): 블록 X=-40~40, Y=-30~30, Z=-30~30. 유로 구멍 Ø20이 X방향 전장 관통, 양 끝에 배관용 카운터보어 Ø26 (X=30~40, X=-40~-30). 내부 캐비티: X축 위 원통 Ø48, X=-22~22 (닫힌 공간). 스템 구멍 Ø12가 Z축 위 캐비티에서 윗면 Z=30까지. (2) 볼: 구 Ø40 (중심 원점). 볼 구멍 Ø20이 d 방향 축으로 관통. 윗면에 스템 탱 홈: d 방향으로 길고, e 방향 폭 6 (±3), Z=15에서 구 표면까지 (d 방향으로 전장 관통). (3) 시트 링 2개: 각각 X축 위 환형 원통 외경 Ø48, 내경 Ø20, 하나는 X=15~22, 다른 하나는 X=-22~-15. 볼과 닿는 쪽은 볼 구면(Ø40)으로 깎여 볼에 맞닿는다. (4) 스템 (한 솔리드): 탱 = d 방향 길이 16 (±8), e 방향 두께 6 (±3), Z=15~21인 직육면체 (볼의 홈 안). 축 Ø12가 Z=21~45. 윗끝 사각 10×10 (변은 d, e 방향과 평행)이 Z=45~55. (5) 핸들 (한 솔리드): Z=46~52의 판. 스템 축 기준 d 방향으로 -20부터 +100까지, e 방향 폭 20 (±10), 스템 사각이 끼는 10×10 사각 구멍 (변은 d, e와 평행). 즉 핸들은 볼 구멍과 같은 30° 방향을 가리킨다.”
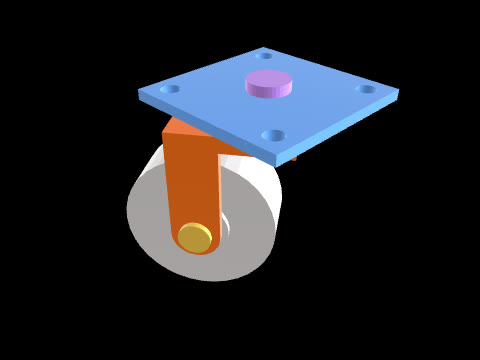
“Model a swivel caster as seven separate solids: top plate, thrust washer, kingpin bolt, nut, fork, wheel, axle. Frame: the kingpin (swivel) axis is the Z axis; the floor is Z=0 and the wheel touches it. Top plate: X=-40..40, Y=-40..40, Z=100..105 (edges parallel to X and Y), Ø12 hole on the Z axis and four Ø9 holes at (±30, ±30), all through along Z. Thrust washer: Ø40, bore Ø12, Z=92..100, on the Z axis. Kingpin bolt: shank Ø12 from Z=78 to Z=105 on the Z axis, head Ø20 from Z=105 to Z=110. Nut: Ø20 cylinder, bore Ø12, Z=78..84. Fork, one solid, described in a fork frame whose origin is on the Z axis: its x axis is the horizontal direction (cos35°, sin35°, 0), its y axis is (-sin35°, cos35°, 0), z = world Z. Crown plate: x=-42..15, y=-23..23, Z=84..92, with a Ø12 hole on the Z axis. Two legs, 5 thick, at y=18..23 and y=-23..-18; each leg (in the x-Z plane) is the rectangle x=-42..-18, Z=37.5..84 united with a disc R12 centred on the axle point (x=-30, Z=37.5), and has a Ø10 axle hole there. So the axle sits 30 behind the kingpin toward the 215° direction, at world (X, Y) = (-24.575, -17.207), Z=37.5. Wheel: axis along the fork y axis through the axle point. Tyre Ø75 over y=-15..15, hub Ø30 over y=-18..18 (the hub faces touch the legs), bore Ø10. Axle: Ø10 along the fork y axis from y=-26 to y=26 through the legs and wheel, with Ø16 heads over y=23..26 and y=-26..-23 bearing on the outer faces of the legs.”
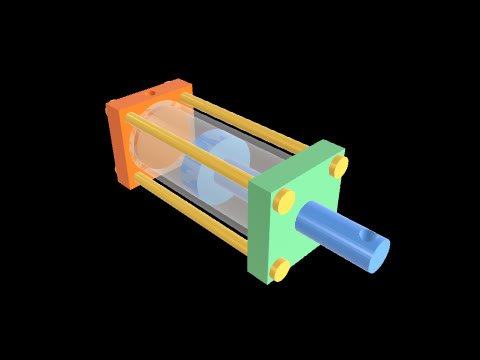
“Model a tie-rod hydraulic cylinder as eight separate solids: base cap, barrel, head cap, piston-and-rod (one solid) and four tie rods. Frame: the cylinder axis is parallel to X through Y=20, Z=35. Offsets 'u, v' below are Y and Z measured from that axis (Y = 20 + u, Z = 35 + v). Base cap: square block X=0..20, u, v = -40..40, with a spigot Ø60 from X=20 to X=25 entering the barrel. Port: a Ø10 hole drilled from the top face (v=40) straight down at X=10, u=0, to the axis, and a Ø8 axial passage on the axis from X=10 to X=25 (opening into the bore). Barrel: tube Ø70 outside, Ø60 inside, X=20..170. Head cap: square block X=170..190, u, v = -40..40, spigot Ø60 from X=165 to X=170, rod bore Ø25 through. Tie-rod holes: both caps have four Ø10 holes along X at (u, v) = (±30, ±30). Piston and rod (one solid): piston Ø60 from X=85 to X=105 (so the piston's base-side face is 60 from the spigot face X=25); rod Ø25 from X=105 to X=250 through the head cap; a Ø12 cross hole through the rod along Z at X=240. Tie rods (four, identical): Ø10 from X=0 to X=190 on (u, v) = (±30, ±30), with heads Ø17 from X=-5 to X=0 and from X=190 to X=195 bearing on the outer faces of the caps.”
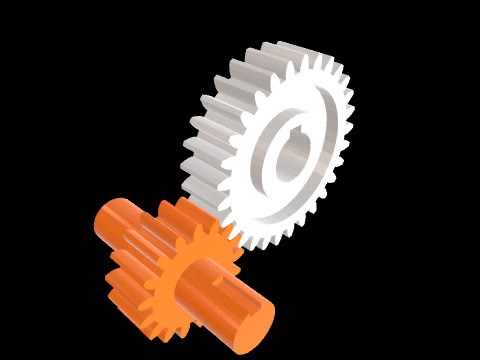
“Model a meshing spur gear pair as two separate solids. Frame: both gear axes are parallel to the X axis. The pinion axis passes through Y=20, Z=-10; the wheel axis passes through Y=99.674, Z=36, so the line of centres runs 30° from +Y toward +Z (centre distance 92). Angular positions about each axis are measured in the YZ plane from +Y toward +Z. Tooth form for both: involute, module 4, pressure angle 20°, no profile shift, addendum 1.0m, root diameter = pitch diameter - 2.5m, root fillets free. Backlash: circular tooth thickness on the pitch circle = pi*m/2 - 0.15 = 6.133, symmetric about the tooth centre line. Both toothed widths span X=0..30. Pinion (a gear shaft, one solid): 17 teeth, pitch Ø68, outside Ø76, root Ø58. Shaft Ø30 from X=-50 to X=0 and from X=30 to X=75. The X=30..75 end has a square-ended keyway 8 wide from X=48 to X=75 on the 90° side (+Z side of the shaft), floor 11 from the pinion axis. Phase: the pinion has a tooth SPACE centred on the 30° direction (toward the wheel). Wheel: 29 teeth, pitch Ø116, outside Ø124, root Ø106. Both side faces are recessed: an annular pocket from Ø56 out to Ø88, 9 deep, is cut into the X=0 face (X=0..9) and into the X=30 face (X=21..30), leaving a web X=9..21. Hub Ø56 from X=-10 to X=30 (it sticks out 10 on the -X side). Ø32 bore through X=-10..30 with a 10 wide keyway on the 90° side over the full length, keyway floor 20.3 from the wheel axis. A radial Ø6.8 set-screw hole at X=-5 runs from the hub surface into the bore on the 0° side (+Y side). Phase: the wheel has a TOOTH centred on the 210° direction from its own axis (toward the pinion), which sits in the pinion's tooth space.”
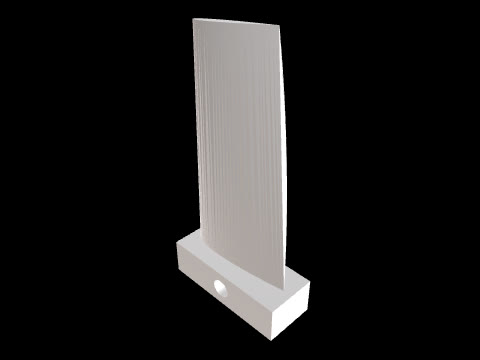
“NACA 대칭 익형 단면 3개를 로프트한 비틀린 블레이드와 루트 블록을 단일 솔리드로 만들어줘. 좌표계: 블레이드 스팬 방향 = +Z, 비틀림 축 = Z축 (각 단면의 1/4 시위점이 Z축 위에 있다). 단면 정의 (단면 평면 Z=z 안의 국부 좌표 x, y): 시위선은 국부 x축 위, 앞전(LE)은 x = -c/4, 뒷전(TE)은 x = 3c/4. 두께 분포는 NACA 4자리 대칭식 y = ±5·t·c·(0.2969·√ξ - 0.1260·ξ - 0.3516·ξ² + 0.2843·ξ³ - 0.1036·ξ⁴), ξ = (x + c/4)/c (0~1), 뒷전은 뾰족하게 닫힌다. 국부 좌표는 +Z에서 내려다볼 때 반시계 방향으로 비틀림각만큼 돌린 뒤 월드에 놓는다 (국부 x축 = (cosθ, sinθ, 0)). - 단면 1: Z=0, 시위 c=60, 두께비 t=0.15 (NACA 0015), 비틀림 θ=0°. - 단면 2: Z=60, c=48, t=0.12 (NACA 0012), θ=15°. - 단면 3: Z=120, c=36, t=0.10 (NACA 0010), θ=30°. 블레이드 = 세 단면을 순서대로 지나는 매끄러운 로프트 (Z=0~120, 끝은 평평). 루트 블록: X=-20~50, Y=-14~14, Z=-20~0 직육면체 (블레이드 루트 면이 그 윗면에 붙는다), Y방향 관통 Ø10 구멍, 축 (X=15, Z=-10).”
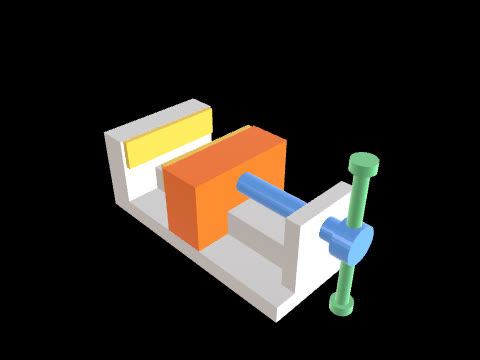
“벤치 바이스를 조립 상태의 분리된 솔리드 6개(몸체, 이동 조, 고정 조 판, 이동 조 판, 스크루, 핸들)로 만들어줘. 좌표계: 조(jaw)가 X방향으로 움직이고, 스크루 축은 X축과 평행한 (Y=0, Z=45) 직선. 바닥면 Z=0. (1) 몸체 (한 솔리드): 베이스 판 X=-60~100, Y=-40~40, Z=0~12. 고정 조 블록 X=-60~-40, Y=-40~40, Z=12~60. 가이드 바 X=-40~90, Y=-15~15, Z=12~30. 엔드 판 X=90~100, Y=-25~25, Z=12~60, 스크루 축 위에 Ø14 구멍이 X방향 관통. (2) 고정 조 판: X=-40~-36, Y=-38~38, Z=40~60 (고정 조 블록의 +X면에 붙는다). (3) 이동 조 (한 솔리드): 블록 X=5.5~35.5, Y=-40~40, Z=12~60에서 가이드를 감싸는 채널 Y=-15~15, Z=12~30을 X방향 전장으로 뺀 형상 (채널 윗면이 가이드 윗면 Z=30에, 옆면이 가이드 옆면에 닿는다). +X면(X=35.5)에서 스크루 축 위로 Ø14 막힌 구멍, 깊이 12 (X=23.5~35.5, 바닥 평평). (4) 이동 조 판: X=1.5~5.5, Y=-38~38, Z=40~60 (이동 조의 -X면에 붙는다). 따라서 두 조 판 사이 벌림(X=-36~1.5)은 37.5. (5) 스크루 (한 솔리드, 나사산은 생략한 원통): Ø14가 X=23.5~110 (끝이 이동 조 막힌 구멍 바닥에 닿고 엔드 판 구멍을 지난다), 머리 Ø24가 X=110~122. 머리에 X=116에서 Z방향 Ø8 관통 구멍. (6) 핸들 (한 솔리드): Ø8 봉이 머리 구멍을 지나 Z방향으로, 축 (X=116, Y=0), Z=0~90. 양 끝에 노브 Ø14: Z=-6~0과 Z=90~96.”
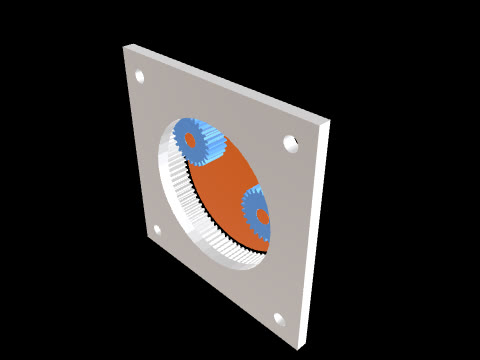
“내접 링기어, 유성기어 2개, 캐리어를 맞물린 조립 상태의 분리된 솔리드 4개로 만들어줘. 좌표계: 링기어 축은 Y축과 평행하고 (X=30, Z=25)를 지난다. 각도는 링 축 둘레로 XZ평면에서 +X에서 +Z 쪽으로 잰다. 유성기어 축도 Y축과 평행. 공통 치형: 인벌류트, 모듈 1.25, 압력각 20°, 전위 없음, 이뿌리 필렛은 자유. (1) 링기어: 잇수 84, 피치원 Ø105, 내치 이끝원 Ø102.5, 내치 이뿌리원 Ø108.125, 피치원 위 이홈 폭은 공칭 π·m/2 = 1.963. 내치는 Y=0~16 전 구간, 링 본체 외경 Ø122 (Y=0~16). 뒤쪽에 사각 플랜지: Y=-8~0, 150×150 (링 축 기준 X, Z 각 ±75, 변은 X축·Z축과 평행), 가운데 구멍 Ø100, Ø9 구멍 4개가 링 축 기준 (X, Z) = (±60, ±60)에서 Y방향 관통. 위상: 링은 0° 방향에 이홈 중심이 온다. (2) 유성기어 2개 (같은 형상): 잇수 26, 피치원 Ø32.5, 이끝원 Ø35, 이뿌리원 Ø29.375, 치폭 Y=0.5~15.5, Ø10 관통 보어. 백래시: 피치원 원호 이두께 π·m/2 - 0.08 = 1.883 (이 중심선에 대칭). 중심거리 36.25로 유성 1은 링 축에서 0° 방향, 유성 2는 135° 방향에 있다. 유성 1은 자기 축에서 바깥쪽(0° 방향)에 이 하나의 중심이 와서 링의 이홈에 들어가고, 유성 2는 바깥쪽(135° 방향)에 이홈 중심이 와서 그 자리에 오는 링의 이가 들어간다. (3) 캐리어 (한 솔리드): 링 축 위 원판 Ø100, Y=16.5~22.5. 두 유성기어 축 위에 Ø9.8 핀이 원판에서 Y=0.5까지 나와 유성 보어에 들어간다 (반경 틈 0.1). 원판 +Y쪽에 링 축 위 Ø20 축이 Y=22.5~45.”
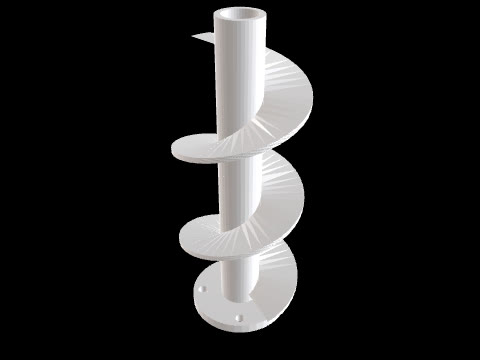
“스크루 컨베이어 축 한 개를 단일 솔리드로 만들어줘 (파이프, 플랜지, 나선 날개가 한 몸). 좌표계: 축은 Z축과 평행하고 (X=-10, Y=20)을 지난다. 각도 θ는 이 축 둘레로 XY평면에서 +X에서 +Y 쪽으로 잰다 (도 단위, 한 바퀴를 넘으면 계속 누적). (1) 파이프: 외경 Ø40, 내경 Ø30 관통, Z=0~300. (2) 플랜지: 외경 Ø100, Z=0~10 (파이프와 한 몸, 가운데는 Ø30 관통), Ø9 관통 구멍 4개가 Ø80 원 위 45°+k·90°. (3) 나선 날개 (오른나사, 피치 100, 축방향 두께 5, 2.5회전): 20 ≤ Z ≤ 270 인 모든 평면 Z=z에서 날개 단면은 반경 20~60, 각도 θ0(z) - 18° 부터 θ0(z) 까지의 환형 부채꼴이다. 여기서 θ0(z) = 3.6·(z - 20) (도). 즉 Z=20에서 부채꼴은 -18°~0°, Z가 100 올라갈 때마다 반시계 방향(+Z에서 볼 때)으로 한 바퀴 돌고, Z=270에서 162°~180°에서 끝난다. 날개 양 끝은 평면 Z=20과 Z=270으로 잘린 면이다. 날개 안쪽 가장자리는 파이프 외면과 한 몸.”
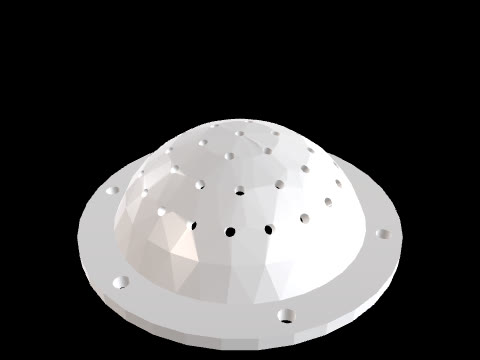
“구면 돔(샤워헤드형) 한 개를 단일 솔리드로 만들어줘. 좌표계: 돔 축은 Z축과 평행하고 (X=15, Y=-5)를 지난다. 구 중심 O = (15, -5, -20). 방위각은 돔 축 둘레로 XY평면에서 +X에서 +Y 쪽으로, 극각은 O에서 +Z 방향으로부터 잰다. (1) 셸: O 중심 외반경 60, 내반경 55인 구 껍질 중 Z≥0 부분 (Z=0 평면에서 잘림, 꼭대기 (15, -5, 40)). (2) 베이스 플랜지: 돔 축 위 환형판 외경 Ø144, 내경 Ø102, Z=-6~0 (셸 아래 끝과 한 몸). Ø6.6 관통 구멍 6개, 돔 축에서 반경 64, 방위각 30°+k·60°. (3) 셸 구멍: 모두 Ø4, 구 중심 O를 향하는 반경 방향 축으로 셸을 관통. - 꼭대기 구멍 1개: 극각 0° (돔 축 위). - 링 A: 극각 15°, 6개, 방위각 0°+k·60°. - 링 B: 극각 30°, 12개, 방위각 15°+k·30°. - 링 C: 극각 45°, 18개, 방위각 10°+k·20°.”
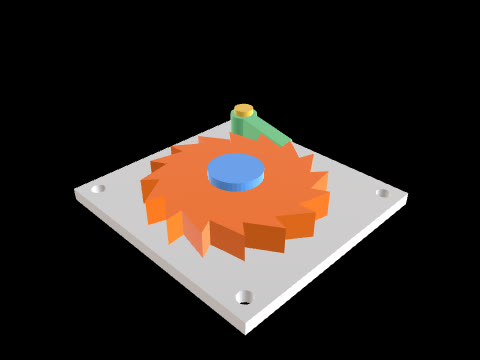
“Model a ratchet-and-pawl mechanism as five separate solids: base plate, shaft, ratchet wheel, pawl and pawl pin. Frame: all axes parallel to Z; angles in the XY plane from +X toward +Y about the ratchet axis, which passes through (10, 0). Base plate: X=-50..60, Y=-45..60, Z=0..6, with a Ø16 hole on the ratchet axis, a Ø6 hole on the pawl axis (below) and four Ø6.6 holes at (X, Y) = (-42, -37), (52, -37), (-42, 52), (52, 52), all through along Z. Shaft: Ø16 from Z=0 to Z=20 on the ratchet axis (sits in the base hole), with a collar Ø24 from Z=20 to Z=24. Ratchet wheel: 16 sawtooth teeth, Z=8..20, bore Ø16 on the shaft, and a spacer hub Ø26 from Z=6 to Z=8 under it. Tooth outline: tip radius 40, root radius 32. For k = 0..15 let a_k = 5° + k·22.5°. Tooth k has a RADIAL face along the ray at a_k from r=32 to r=40, and a straight back flank from the root point (r=32 at a_k) to the tip point (r=40 at a_(k+1)). So every radial face faces counter-clockwise (toward increasing angle) and the wheel can only turn clockwise seen from +Z. Pawl (Z=8..20): a straight bar, outline = quadrilateral (7.101, 33.135), (6.368, 41.511), (-29.714, 49.800), (-31.505, 42.003) (world XY), plus a boss Ø14 from Z=6 to Z=20 centred on the pawl axis (-30.609, 45.902), with a Ø6.2 hole on that axis. The edge (7.101, 33.135)-(6.368, 41.511) lies on the ray at 95° from the ratchet axis, so the pawl's end face bears flat on the radial face of tooth k=4; the bar's lower edge runs 1.2 above the back flank of tooth k=4. Pawl pin: Ø6 on the pawl axis from Z=0 to Z=20 (in the base hole), head Ø10 from Z=20 to Z=23.”
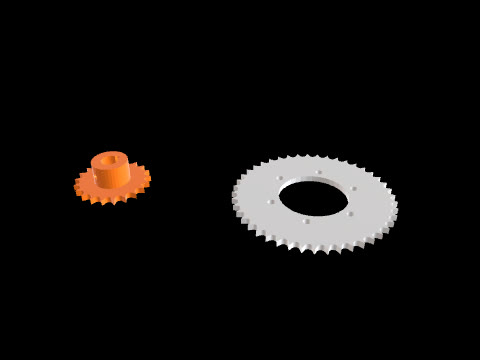
“Model two roller-chain sprockets for ISO 606 06B single-strand chain as two separate solids on a fixed centre distance; the chain itself is not modelled. Chain pitch p = 9.525, roller Ø6.35. Frame: both axes parallel to Z; sprocket A's axis passes through (20, -30), sprocket B's through (164, 78), so the line of centres from A to B points at 36.870° (centre distance 180). Both tooth plates occupy Z=0..5.3 (one chain line). Angles are measured in the XY plane from +X toward +Y about each sprocket's own axis. Tooth form, ISO 606 construction with these exact values: pitch diameter d = p / sin(180°/z). Around each roller centre on the pitch circle, a roller-seat arc of radius ri spans the seating angle, symmetric about the line from the roller centre to the sprocket centre. From each end of the seat arc a convex flank arc of radius re continues tangentially; its centre lies on the line from the roller centre through that seat-arc end, re beyond the end. The flanks are cut off by the tip circle da. Root diameter = d - 2ri. No tooth side chamfer. Sprocket A: 21 teeth, d = 63.908, ri = 3.30, seating angle 124°, re = 24, da = 68, root Ø57.308. Hub Ø32 from Z=5.3 to Z=25. Ø15 bore through Z=0..25 with a 5 wide keyway on the 90° side, floor 9.8 from the axis. A radial Ø5 set-screw hole at Z=15 runs from the hub surface into the bore on the 270° side. Phase: a TOOTH of A is centred on the 36.870° direction (pointing at B), so A's roller seats sit at 36.870° ± 8.571°. Sprocket B (plate type, no hub): 45 teeth, d = 136.546, ri = 3.30, seating angle 126°, re = 60, da = 141, root Ø129.946. Centre hole Ø60 through the plate; six Ø6.6 bolt holes through the plate on a Ø76 circle about B's axis at 0° + k·60°. Phase: a roller seat of B is centred on the 216.870° direction from B's axis (pointing at A).”
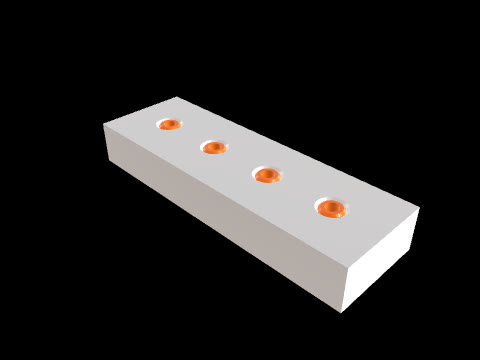
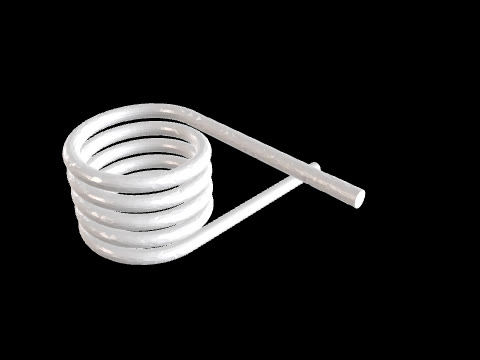
“Model a torsion spring as ONE solid (wire and legs in one piece). Frame: coil axis parallel to Z through (X=8, Y=-6); angles about it are measured in the XY plane from +X toward +Y. Wire: round, Ø3, swept along the path below (section perpendicular to the path). Coil: helix of radius 12 (wire centre), pitch 4, LEFT-hand, 4.75 turns, from Z=0 to Z=19. It starts at Z=0 on the 0° side, at (20, -6, 0). Left-hand: the angle DEcreases as Z increases (clockwise seen from +Z), angle = -90°·Z, so at Z=1 the wire centre is on the 270° side (8, -18, 1) and at Z=19 it ends on the 90° side at (8, 6, 19). Leg 1: straight, in the plane Z=0, tangent to the coil at its start: from (20, 34, 0) to the start point (20, -6, 0), i.e. it runs along -Y into the coil. Leg 2: straight, in the plane Z=19, tangent to the coil at its end: from the end point (8, 6, 19) along +X to (48, 6, 19). At both joints the wire is continuous (fill the joint with a Ø3 sphere); leg ends are flat.”
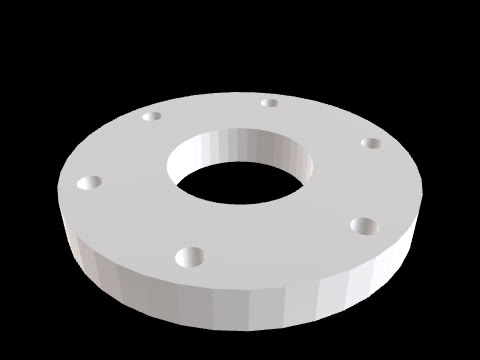
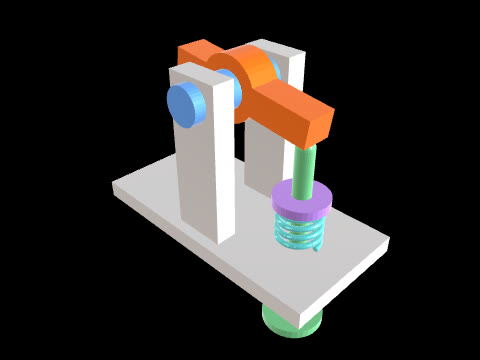
“Model a rocker-arm valve train as seven separate solids: pedestal, rocker shaft, rocker arm, valve, spring retainer, valve spring, pushrod. Frame: the rocker shaft axis is parallel to Y through X=0, Z=60; Z is up. Pedestal (one solid): base plate X=-60..60, Y=-30..30, Z=-8..0; two cheeks X=-12..12, Z=0..70, at Y=15..25 and Y=-25..-15, each with a Ø16 hole on the shaft axis. The base plate has a Ø8 hole for the valve stem and a Ø10 clearance hole for the pushrod (axes below), both through along Z. Rocker shaft: Ø16 along Y from Y=-30 to Y=30. Rocker arm (one solid, Y=-7..7), defined in an arm frame with origin on the shaft axis, arm x along the arm and arm z across it: a hub Ø28 with a Ø16 bore on the shaft, united with a beam x=-30..40, z=-6..6. The arm is rotated about the shaft axis by 8° so that its +X end goes DOWN: arm x = (cos8°, 0, -sin8°), arm z = (sin8°, 0, cos8°). Valve (one solid): vertical stem Ø8 whose axis is X=34.258, Y=0, from Z=-40 up to Z=45.087, capped by a hemisphere R4 centred at (34.258, 0, 45.087); this tip touches the arm's lower face (arm z=-6) at arm x=36. Head: disc Ø28 from Z=-44 to Z=-40. Spring retainer: disc Ø24, bore Ø8, Z=20..24 on the valve axis. Valve spring: round wire Ø2.5 swept along a helix around the valve axis, coil radius 9, right-hand, 4 turns from Z=1.25 to Z=18.75 (pitch 4.375), starting on the +X side of the valve axis; it rests on the base plate (Z=0) and touches the retainer (Z=20). Pushrod (one solid): vertical rod Ø6 with axis X=-25.158, Y=0, from Z=-40 up to Z=53.437, with a ball Ø8 centred at (-25.158, 0, 53.437); the ball touches the arm's lower face at arm x=-24.”
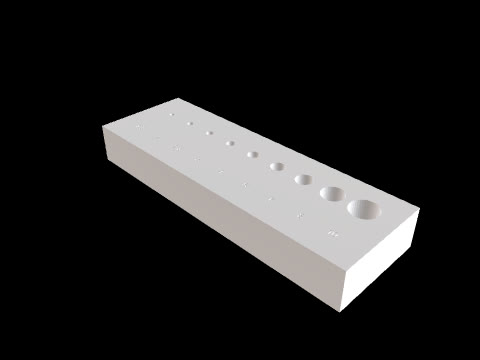
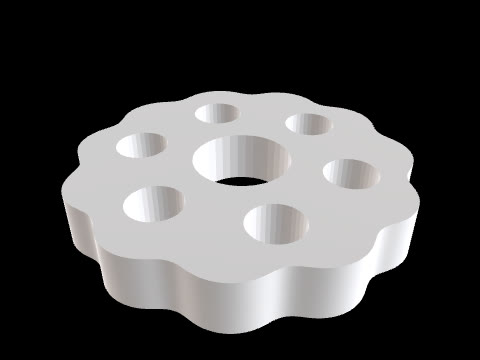
“Model a cycloidal-reducer disc as ONE solid. Frame: disc axis parallel to Z through (X=5, Y=-8); disc coordinates (x, y) are measured from that point with x parallel to world X and y parallel to world Y. Thickness Z=0..12. Outline: the curve for t = 0..2·pi (the standard cycloidal-disc profile for N = 12 ring pins on a pin circle of radius R = 40, pin radius Rr = 3, eccentricity E = 1.5, giving N-1 = 11 lobes): x(t) = R·cos t - Rr·cos(t + psi) - E·cos(N·t) y(t) = -R·sin t + Rr·sin(t + psi) + E·sin(N·t) psi(t) = atan2( sin((1-N)·t), R/(E·N) - cos((1-N)·t) ). At t = 0 this gives the point (35.5, 0): a valley (minimum radius 35.5) on +x; the lobe tips (radius 38.5) are halfway between valleys, the first at 16.364° (360°/22) from +x. Holes through Z=0..12: a Ø22 centre bore on the disc axis, and six Ø12 output-pin holes on a Ø48 circle at 30° + k·60° (angles from +x toward +y).”
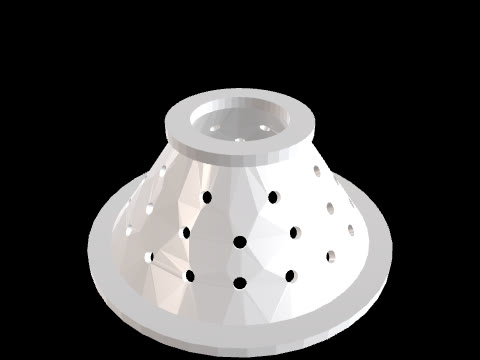
“Model a perforated conical shell as ONE solid. Frame: cone axis parallel to Z through (X=12, Y=12); azimuth phi is measured about that axis in the XY plane from +X toward +Y. Shell: the outer surface is the cone r_o(z) = 70 - (2/3)·z for z = 0..60 (radius 70 at Z=0, 30 at Z=60). The wall is 4 thick measured normal to that surface, so the inner surface is r_i(z) = 65.193 - (2/3)·z. The shell is cut by the planes Z=0 and Z=60. Bottom ring: annulus inner Ø124, outer Ø164, Z=-6..0. Top ring: annulus inner Ø48, outer Ø72, Z=60..66. Both are merged with the shell. Holes: Ø6, each drilled through the wall along the outward surface normal of the outer cone at a point P on the outer surface, i.e. along the direction (cos phi, sin phi, 2/3)/1.20185 (tilted up 33.69° from horizontal): - Row 1: P at z=15 (r_o=60), 16 holes at phi = 0° + k·22.5°. - Row 2: P at z=30 (r_o=50), 12 holes at phi = 15° + k·30°. - Row 3: P at z=45 (r_o=40), 8 holes at phi = 22.5° + k·45°.”
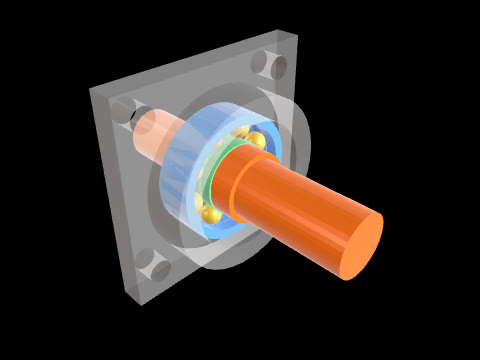
“깊은 홈 볼베어링이 들어간 하우징과 축을 조립 상태의 분리된 솔리드 12개(하우징, 외륜, 내륜, 볼 8개, 축)로 만들어줘. 좌표계: 공통 축은 X축과 평행하고 (Y=-15, Z=35)를 지난다. 각도는 축 둘레로 YZ평면에서 +Y에서 +Z 쪽으로 잰다. 아래 반경은 이 축에서 잰다. (1) 하우징 (한 솔리드): 사각 플랜지 X=0~10, 축 기준 Y·Z 각 ±40 (80×80, 변은 Y축·Z축과 평행), Ø9 볼트 구멍 4개가 축 기준 (Y, Z) = (±30, ±30)에서 X방향 관통. 보스 Ø64가 X=10~26. 보어: X=0~5는 Ø38 (외륜을 받치는 턱), X=5~26은 Ø47 (베어링 시트). (2) 외륜: 외경 Ø47, 내경 Ø40, X=5~19 (폭 14), X=5 면이 하우징 턱에 닿는다. (3) 내륜: 내경 Ø20, 외경 Ø27, X=5~19. 궤도홈: 외륜 안쪽과 내륜 바깥쪽에 반경 4.1의 원형 단면 홈. 홈 단면 원의 중심은 X=12 평면에서 반경 16.75의 원 위 (즉 반경 16.75 피치원을 도는 토러스로 두 링을 깎은 것). (4) 볼 8개: 각각 Ø8 구, 중심은 X=12, 반경 16.75의 피치원 위, 20° + k·45° (k=0..7) 방향. 즉 볼 하나의 중심이 20° 방향에 온다. 볼은 두 궤도홈과 0.1 틈. (5) 축 (한 솔리드): Ø20이 X=-30~19 (내륜 보어에 맞닿음, 하우징 턱 구멍 Ø38은 닿지 않고 지난다), 칼라 Ø26이 X=19~28 (X=19 면이 내륜 X=19 면에 닿는 축 턱), Ø22가 X=28~70. Ø22 구간에 0° 쪽(+Y쪽) 폭 6 키홈이 X=40~62 (끝은 직각), 키홈 바닥은 축에서 8.5.”
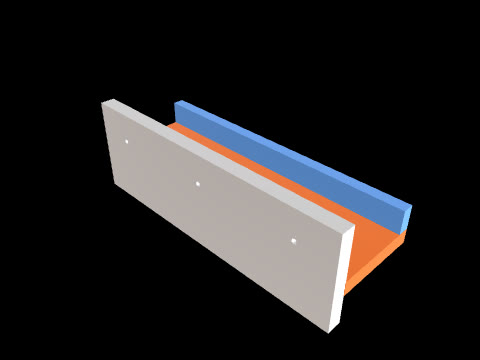
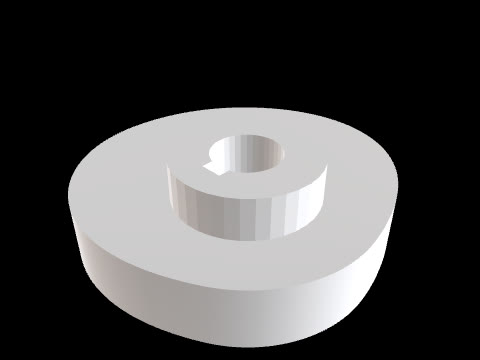
“Model a plate cam as ONE solid. Frame: cam axis parallel to Z through (X=10, Y=5); the polar angle phi is measured about that axis in the XY plane from +X toward +Y, in the cam's own (fixed) frame as modelled. Pitch curve (path of the centre of an in-line roller follower of radius 8): r(phi) = 38 + s(phi), with s in mm and phi in degrees: - 0 <= phi < 120: cycloidal rise, s = 14·(phi/120 - sin(2·pi·phi/120)/(2·pi)). - 120 <= phi < 180: dwell, s = 14. - 180 <= phi < 300: simple-harmonic return, s = 7·(1 + cos(pi·(phi-180)/120)). - 300 <= phi < 360: dwell, s = 0. Cam profile: the inner envelope of the roller circle (radius 8) moving along the pitch curve, i.e. the pitch curve offset inward by 8 along its normal (base circle radius 30, maximum radius 44). The profile is extruded from Z=0 to Z=15. Hub: Ø34 from Z=15 to Z=25 on the cam axis. Bore Ø16 through Z=0..25 with a 5 wide keyway on the 270° side (phi = 270°), full length, floor 10.3 from the axis.”
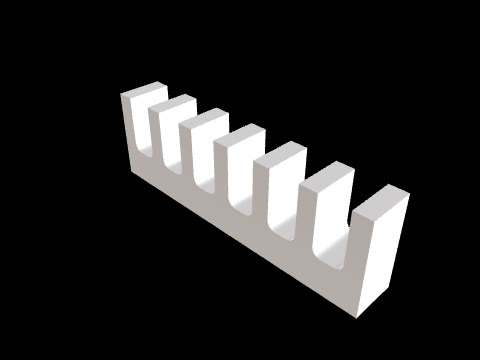
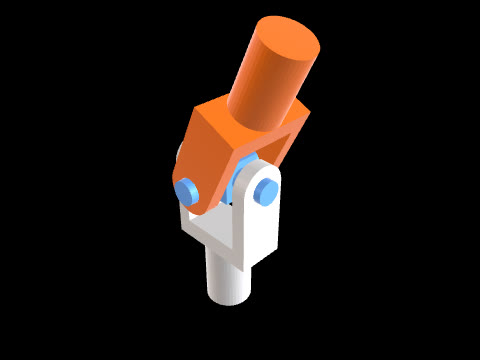
“유니버설 조인트(카르단)를 조립 상태의 분리된 솔리드 3개(요크 A, 요크 B, 십자축)로 만들어줘. 좌표계: 조인트 중심(십자축 중심) C = (10, -5, 60). (1) 십자축 (한 솔리드): C 중심의 정육면체 16×16×16 (변은 X, Y, Z축과 평행), 여기서 트러니언 4개: X방향 Ø10 원통이 C에서 X=-22~+22 (C 기준), Y방향 Ø10 원통이 C에서 Y=-22~+22 (C 기준). (2) 요크 A (입력, 축이 C 아래로 -Z 방향): 귀(ear) 2개는 두께 6의 판으로 X방향 트러니언을 잡는다. 귀는 C 기준 X=13~19 와 X=-19~-13, Y=-10~10, 아래로 Z=-26부터 위로 C 높이까지의 직사각형에 X축(트러니언 축) 둘레 R10 반원을 합친 윤곽. 귀마다 트러니언 축 위 Ø10.2 구멍. 두 귀는 바닥 블록 X=-19~19, Y=-10~10, Z=-34~-26 (모두 C 기준)으로 이어지고, 블록 아래 Ø20 축이 Z=-64~-34 (C 기준, 축은 C를 지나는 연직선). (3) 요크 B (출력): 요크 A와 같은 치수이지만 Y방향 트러니언을 잡고(귀는 C 기준 Y=13~19 와 Y=-19~-13), 축 방향은 w = (sin25°, 0, cos25°) = (0.42262, 0, 0.90631), 즉 C에서 위쪽으로 +X 쪽으로 25° 꺾여 있다 (십자축의 Y 트러니언 둘레로 25° 회전). 요크 B의 자기 좌표에서: 귀는 w 방향으로 -10~26 (트러니언 축 둘레 R10 반원 + 직사각형), 폭은 e = (cos25°, 0, -sin25°) 방향으로 ±10, 바닥 블록은 w 방향 26~34, e 방향 ±10, Y 방향 ±19, 축 Ø20이 w 방향 34~64. 모든 구멍과 트러니언 사이 반경 틈 0.1. 부품끼리 서로 파고들지 않는다.”
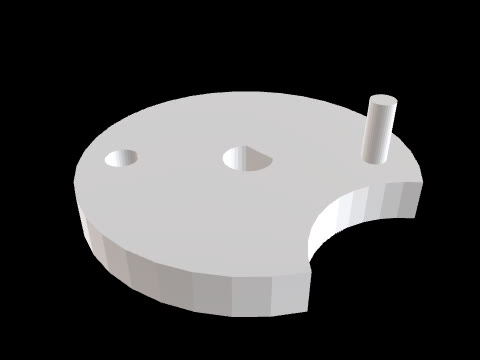
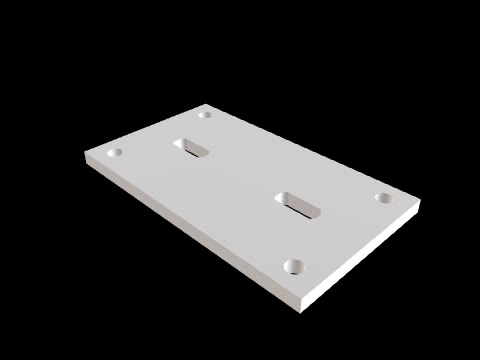
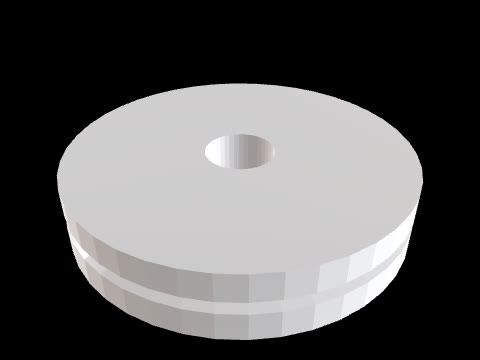
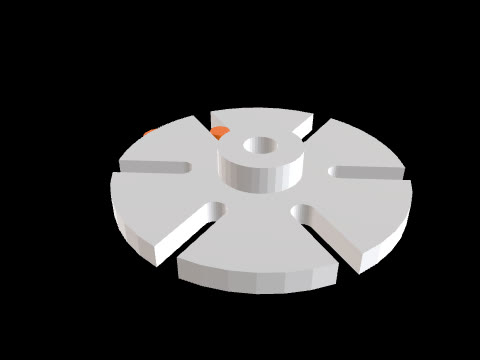
“Model a six-slot Geneva drive, assembled, as 2 separate solids: the driver (crank + drive pin) and the Geneva wheel. Frame: both axes parallel to Z; driver axis through (-20, 15), wheel axis through (40, 15) (centre distance 60). Angles in the XY plane from +X toward +Y about each part's own axis. Geneva wheel: plate Ø104, Z=0..8, with six radial slots 8.2 wide, one every 60°. Each slot runs along its centre line from the rim inward and ends in a semicircle whose centre is 28 from the wheel axis. Hub Ø30 on top, Z=8..18; Ø12 bore through Z=0..18. Driver: crank arm 14 wide, Z=-7..-1 (1 below the wheel), from the driver axis to the pin centre, 30 long between centres, both ends rounded R7. Hub Ø24 under the arm, Z=-20..-7, Ø10 bore through Z=-20..-1. Drive pin Ø8 on the arm end, from Z=-1 up to Z=8, one solid with the arm. Position: the crank points at 20° (measured from the line of centres, which points at 0°), so the pin centre is at (8.191, 25.261). The wheel is turned so that one slot's centre line passes through the pin centre: that slot points at 162.122° from the wheel axis (the pin centre is 33.423 from the wheel axis), and the other slots are at 162.122° + k·60°. The pin sits in the slot with 0.1 clearance each side.”
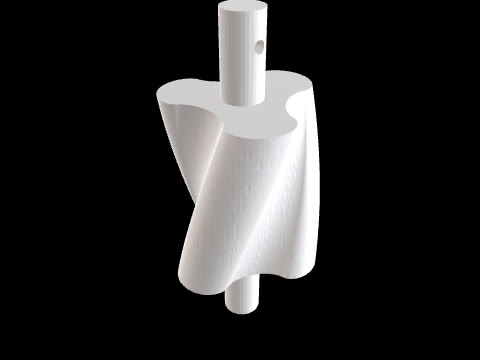
“3엽 루츠 블로어 로터 한 개를 단일 솔리드로 만들어줘. 좌표계: 로터 축은 Z축과 평행하고 (X=-20, Y=15)를 지난다. 단면 좌표 (x, y)는 이 축에서 잰 값 (x ∥ +X, y ∥ +Y), 각도는 +x에서 +y 쪽으로. Z=0 단면 윤곽: 피치원 반경 R=30 위를 반경 a=5의 원이 굴러 만드는 6개의 원호 (각각 피치원 60° 구간): - 엽(lobe) 원호 = 외전 사이클로이드: x = (R+a)·cosθ - a·cos((R+a)·θ/a), y = (R+a)·sinθ - a·sin((R+a)·θ/a), θ = 0~60°. 이 원호를 0°, 120°, 240°만큼 돌린 3개 (엽 끝 반경 40이 30°, 150°, 270° 방향). - 골(root) 원호 = 내전 사이클로이드: x = (R-a)·cosθ + a·cos((R-a)·θ/a), y = (R-a)·sinθ - a·sin((R-a)·θ/a), θ = 0~60°. 이 원호를 60°, 180°, 300°만큼 돌린 3개 (골 바닥 반경 20이 90°, 210°, 330° 방향). 로터 몸체: 이 윤곽을 Z=0에서 Z=90까지 나선형으로 밀어낸 것. 단면은 Z가 커질수록 +Z에서 볼 때 반시계 방향으로 돌아, Z=90에서 60° 돌아가 있다 (회전각 = 60°·Z/90, 균일). 축: Ø20 저널이 Z=-40~0 과 Z=90~130 (로터와 한 몸). Z=115에서 X방향 Ø6 크로스 구멍이 저널을 관통.”
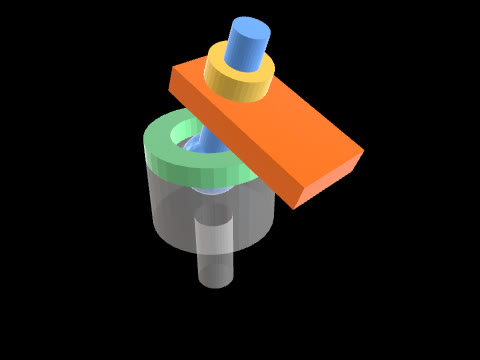
“볼 조인트를 조립 상태의 분리된 솔리드 5개(하우징, 캡, 볼 스터드, 레버 판, 너트)로 만들어줘. 좌표계: 볼 중심 C = (15, -10, 30). 하우징 축은 C를 지나는 연직선(Z축과 평행). 스터드 축 방향 s = (sin20°, 0, cos20°) = (0.34202, 0, 0.93969), 즉 연직에서 +X 쪽으로 20° 기울어 있다. t = (cos20°, 0, -sin20°) 는 s에 수직인 XZ평면 안 방향. (1) 하우징 (한 솔리드): C 축 위 원통 Ø50, Z=5~35, 아래로 Ø16 생크가 Z=-30~5. 내부: C 중심 반경 12.5의 구면 소켓 (C 아래쪽 반구) 과 Ø25 원통 보어 Z=30~35. (2) 캡 (한 솔리드): C 축 위 원판 Ø50, Z=35~43. 안쪽은 C 중심 반경 12.5 구면으로 깎이고, 가운데 Ø30 관통 구멍. (3) 볼 스터드 (한 솔리드): 볼 Ø25 (중심 C), 목 Ø14가 s 방향으로 C에서 거리 0~30, 생크 Ø12가 거리 30~60 (모두 s 축 위). (4) 레버 판: s에 수직인 판, s 방향 거리 30~40 (목의 어깨 면에 앉는다). 판 안에서 t 방향 -15~45, Y 방향 ±15. 생크가 지나는 Ø12 구멍이 s 축 위. (5) 너트: s 축 위 원통 Ø22, 보어 Ø12, s 방향 거리 40~48 (레버 판 위에 닿는다). 볼은 소켓·캡의 구면과 닿고 모든 부품은 서로 파고들지 않는다.”
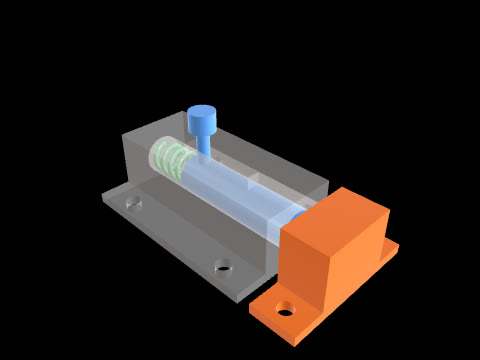
“스프링 걸쇠(슬라이드 래치)를 빗장이 걸림쇠에 들어간 상태로 분리된 솔리드 4개(하우징, 빗장, 압축 스프링, 걸림쇠)로 만들어줘. 좌표계: 빗장 축은 X축과 평행하고 (Y=12, Z=10)을 지난다. 축 둘레 각도는 YZ평면에서 +Y에서 +Z 쪽으로 잰다. (1) 하우징 (한 솔리드): 블록 X=0~60, Y=0~24, Z=0~20. 바닥 부착판 Z=0~3이 X=0~60, Y=-10~34, Z방향 Ø4.5 구멍 4개 (X, Y) = (10, -5), (50, -5), (10, 29), (50, 29). 빗장 축 위 Ø12.2 보어가 X=4~60 (X=60 쪽 열림, X=0~4는 막힌 끝벽). 윗면 슬롯: 폭 4.2 (Y=9.9~14.1), X=18~44 (끝은 직각), 보어에서 윗면 Z=20까지 관통. (2) 빗장 (한 솔리드): Ø12 원통이 빗장 축 위 X=20~70. 손잡이 Ø4 핀이 X=24에서 빗장 축부터 +Z로 Z=26까지 (슬롯을 지난다), 그 위 Ø8 노브가 Z=26~32. (3) 압축 스프링: 선경 Ø1.6 (원형 단면), 코일 평균 지름 Ø9 (선 중심이 축에서 반경 4.5), 오른감기, 4회전. 선 중심의 나선은 X=4.8에서 X=19.2까지 (피치 3.6), 끝은 연마하지 않은 채 잘린 그대로이고, 선이 X=4 끝벽과 X=20 빗장 뒷면에 닿는다. 시작점: X=4.8에서 선 중심은 축의 +Z쪽 (Y=12, Z=14.5). 오른감기이므로 X가 커질수록 선 중심 각도가 +Y에서 +Z 쪽 방향으로 증가한다 (X=5.7에서 180°, 즉 (Y=7.5, Z=10)). (4) 걸림쇠 (한 솔리드): 블록 X=64~78, Y=0~24, Z=0~20, 바닥판 Z=0~3이 X=64~78, Y=-10~34, Z방향 Ø4.5 구멍 2개 (71, -5), (71, 29). 빗장 축 위 Ø12.4 막힌 구멍 X=64~74. 빗장 끝(X=70)이 6 들어가 있다.”
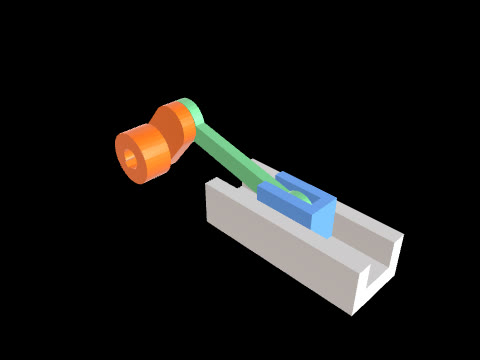
“Model an in-line slider-crank mechanism, assembled at one crank angle, as 4 separate solids: crank, connecting rod, slider and guide. Frame: the crank axis is parallel to Y through X=10, Z=5. The slider moves along the line parallel to X through Z=5 (in line with the crank axis). Angles are measured in the XZ plane from +X toward +Z. Crank (one solid): hub Ø30 on the crank axis from Y=-16 to Y=0; arm Y=0..8, a straight 24 wide bar from the crank axis to the crank-pin centre 25 away, both ends rounded R12 about those two centres; crank pin Ø10 from Y=8 to Y=15. Ø12 bore on the crank axis through Y=-16..8 with a 4 wide keyway pointing away from the crank pin (230°), floor 7.8 from the axis. Position: the crank points at 50°, so the crank-pin centre is at X=26.070, Z=24.151. Connecting rod: Y=8.2..14.2, 80 between centres. Big eye Ø24 with a Ø10.2 hole on the crank pin; small eye Ø18 with a Ø8.2 hole on the wrist pin; the eyes are joined by a straight shank 10 wide centred on the line between the centres. Slider (one solid, wrist pin included): the wrist-pin centre is on the slide line at X=103.744 (so the rod length is exactly 80). Block X=87.744..119.744 (wrist pin -16..+16), Z=-6..16, Y=2..20. A slot for the rod, Y=7.7..14.7, runs through the full block height and from the block's -X face to X=114.744 (wrist pin +11), leaving a 5 thick bridge at the +X end. Wrist pin Ø8 along Y from Y=2 to Y=20 on the wrist-pin centre, bridging the slot. Guide (one solid): base plate X=60..150, Y=-6..28, Z=-16..-6 (the slider rests on its top face Z=-6), and two side walls X=60..150, Z=-6..8, at Y=-6..2 and Y=20..28, touching the slider's Y=2 and Y=20 faces.”
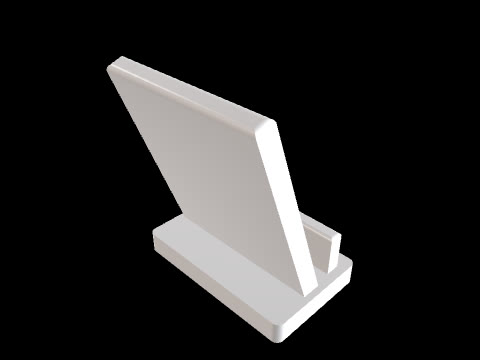
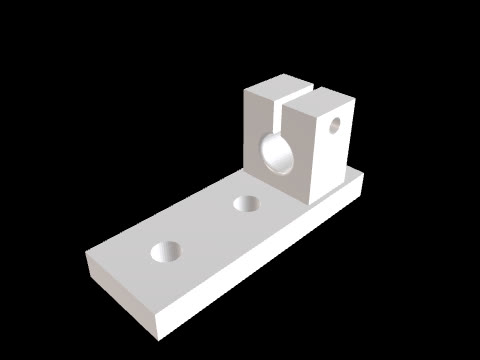
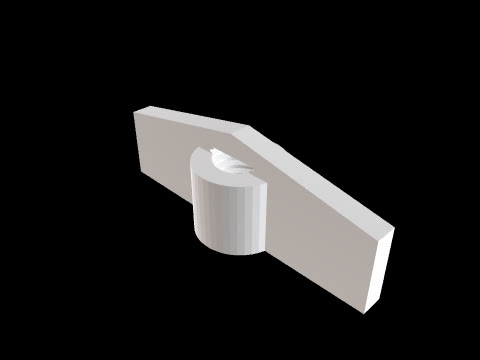
“Model a scissor link, assembled, as 3 separate solids: bar A, bar B and the pivot pin. Frame: the pivot axis is parallel to Z through X=15, Y=20. Angles in the XY plane from +X toward +Y. Distances along a bar are measured from the pivot axis along that bar's direction. Both bars have the same stadium outline in plan: 16 wide, straight sides, semicircular ends of radius 8 centred at -60 and +60 along the bar (overall length 136), with a Ø8.2 pivot hole on the pivot axis. Bar A: 5 thick, Z=0..5, its direction points at 35°. It has a Ø6.2 hole at -60 and, at the + end, a slot 6.2 wide along the bar with semicircular ends whose centres are at +48 and +60. Bar B: 5 thick, Z=5.2..10.2 (0.2 above bar A), its direction points at 145°, so the bars cross at 110°. It has Ø6.2 holes at -60 and +60. Pivot pin: Ø8 shank on the pivot axis from Z=-4 to Z=10.2, head Ø14 from Z=10.2 to Z=12.2 seated on bar B's top face, and a Ø2.5 split-pin hole through the shank along the X direction at Z=-1.5.”
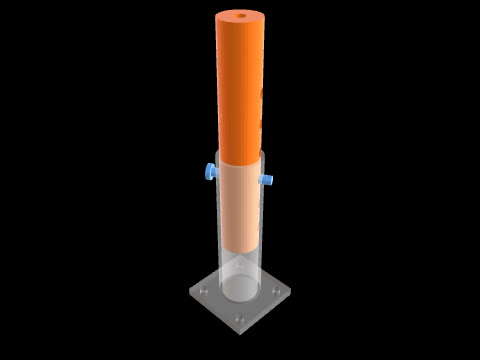
“텔레스코픽 원형 파이프 2개를 크로스 핀으로 고정한 조립체를 분리된 솔리드 3개(바깥 파이프, 안쪽 파이프, 핀)로 만들어줘. 좌표계: 두 파이프의 공통 축은 Z축과 평행하고 (X=12, Y=-8)을 지난다. 각도는 XY평면에서 +X에서 +Y 쪽으로 잰다. 핀 축은 Z=130 높이에서 파이프 축과 직교하며 방향 d = (cos30°, sin30°, 0) = (0.86603, 0.5, 0). 아래에서 s는 파이프 축에서 d 방향으로 잰 거리. (1) 바깥 파이프 (한 솔리드): 외경 Ø40, 내경 Ø34, Z=0~150. 아래 끝에 사각 받침판 Z=-8~0, 70×70 (파이프 축 기준 X, Y 각 ±35, 변은 X축·Y축과 평행), 받침판은 막혀 있고 Ø7 구멍 4개가 파이프 축 기준 (±25, ±25)에서 Z방향 관통. 핀 구멍 Ø8.4가 Z=130에서 d 방향으로 양쪽 벽 관통. (2) 안쪽 파이프 (한 솔리드): 외경 Ø33.8 (바깥 파이프와 반경 틈 0.1), 내경 Ø27.8, Z=60~260. 위 끝은 두께 8의 마개로 막혀 있다 (Z=252~260, 가운데 Ø10 구멍 관통, 속 빈 부분은 Z=60~252). 핀 구멍 Ø8.4 쌍 6개가 d 방향으로 양쪽 벽 관통, 높이는 아래 끝에서 20 + k·25 (k=0..5), 즉 Z=80, 105, 130, 155, 180, 205. 아래에서 세 번째 구멍(k=2, Z=130)이 바깥 파이프의 핀 구멍과 맞춰져 있다. (3) 핀 (한 솔리드): Ø8 축부가 핀 축 위 s=-24~27, 머리 Ø14가 s=-28~-24 (머리는 d의 음의 쪽, 머리 안쪽 면은 바깥 파이프 표면에서 떨어져 있다). 끝 쪽 s=24에 클립용 Ø2.5 구멍이 Z방향으로 축부를 관통.”
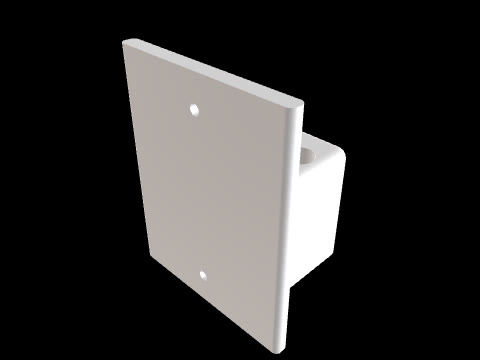
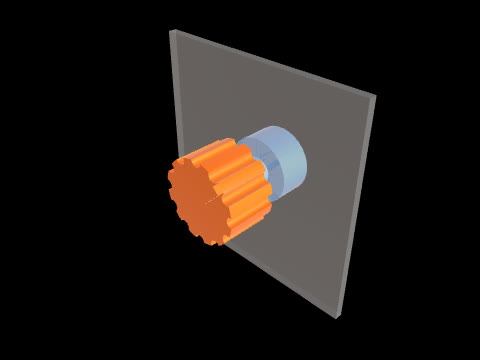
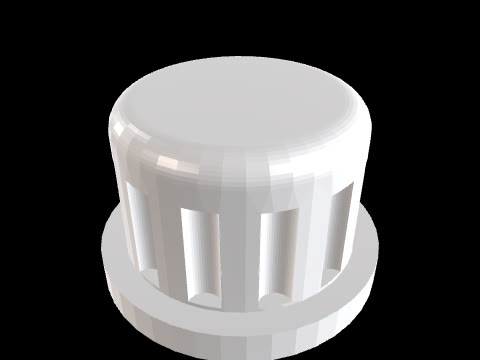
“Model a control knob on a D-shaft potentiometer mounted in a panel, assembled, as 4 separate solids: panel, potentiometer (body, bushing and shaft as one solid), knob, set screw. Frame: the shaft axis is parallel to Y through X=-30, Z=40; the knob is on the -Y side of the panel. Angles are measured about the shaft axis in the XZ plane from +X toward +Z; radii are from the shaft axis. Panel: plate Y=0..3, X=-70..10, Z=0..80, with a Ø10 hole on the shaft axis. Potentiometer (one solid): body Ø24 from Y=3 to Y=15 (against the panel's back face), bushing Ø10 from Y=0 to Y=3 filling the panel hole, shaft Ø6 from Y=0 to Y=-20. D-flat: from Y=-10 to the shaft tip Y=-20 the shaft is cut by a plane 1.5 from the axis whose outward normal points at 225°. Knob (one solid): cylinder Ø30 from Y=-6 to Y=-24 (6 clear of the panel). Twelve grip flutes: semicircular grooves R2 along Y over the full knob length, their centres on radius 15 at 0° + k·30°. Pointer: a raised rib on the front face, 3 wide, Y=-26..-24, running radially from radius 5 to radius 15 along the 45° direction (diametrically opposite the flat). Blind bore Ø6.1 on the axis from Y=-6 to Y=-21. A Ø3 radial set-screw hole at Y=-14 runs from the bore to the knob surface along the 225° direction. Set screw: a plain Ø3 cylinder in that hole, on the 225° line at Y=-14, from radius 1.5 (its flat end bearing on the shaft's D-flat) out to radius 12 (3 below the knob surface).”
Ready to create your own?
Describe a part, inspect the result, and refine it before exporting.